
Last week, Wayve launched a robotaxi service in London in partnership with Uber. The Cambridge-founded autonomy company, backed by Mercedes-Benz, Nissan and Stellantis, started putting its AI-driven self-driving system on the city’s streets. A safety driver still sits behind the wheel and full driverless operation awaits further permitting. Even so, it is one of the clearest signs yet that the robotaxi has moved from demonstration to deployment in the UK.
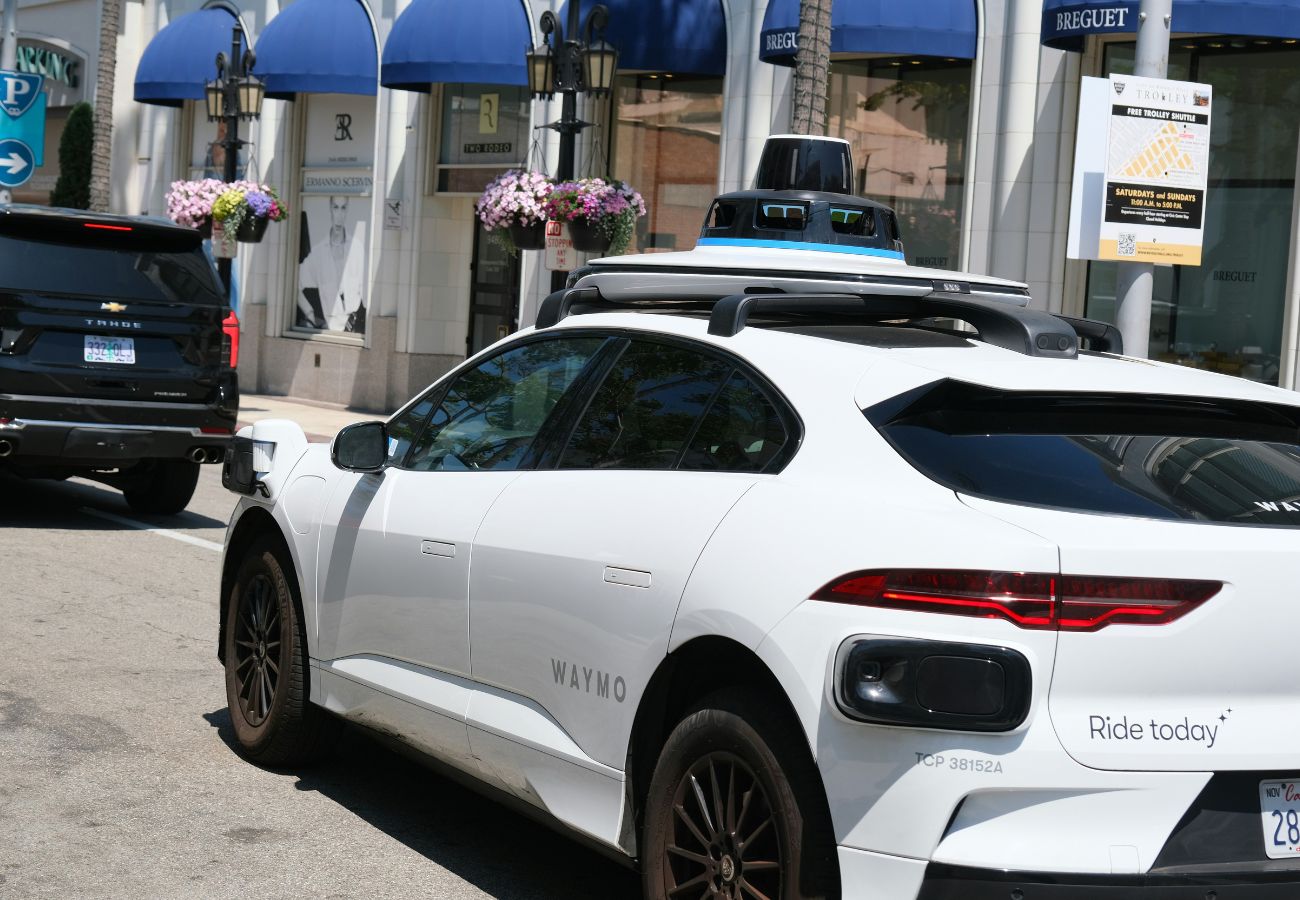
Wayve currently faces competition from Google-owned Waymo and Chinese company Baidu, both of whom are testing in London. In the US, Waymo has scaled from 50,000 paid rides a week in mid-2024 to around 500,000 a week across ten cities, and has set a public target of one million weekly rides by the end of 2026. Urban demand is real and growing.
As robotaxis move from mapped test routes into the dense, unpredictable reality of major cities, one question sits beneath every self-driving stack: how does the car know, reliably, where it is?
Urban deployment raises the demands on the whole system
A self-driving vehicle is only as capable as the environment it can read – and cities are the hardest environments there are. As Bloomberg noted, London’s irregular street layout presents challenges that Los Angeles and San Francisco do not. Wayve and Uber have themselves acknowledged that UK cities are complex driving environments with road layouts and traffic dynamics markedly different from US testing grounds.
In the words of Muhammad Nauman Nasir, ADAS lead at Mercedes-Benz, “The technology ceiling for autonomous vehicles is set by the infrastructure floor of the cities they operate in.” As the environment gets tougher, the vehicle has to get smarter. The systems it depends on have to hold up precisely where they’re most likely to fail.
The UK’s Automated Vehicles Act requires self-driving vehicles to prove they are at least as safe as a competent, careful human driver before approval.
Japan takes a different route: its rules currently require a person in the driver’s seat regardless of autonomy level, and a licensed local taxi operator must run any commercial fleet. Tokyo’s solution was to bring in Hinomaru Kotsu to manage vehicles, positioning robotaxis as a supplement to a shrinking, ageing driver workforce rather than a replacement.
In every case, the safety argument a company must make to regulators rests on the vehicle knowing, verifiably, where it is and how its systems fail. That makes positioning integrity foundational.
The GNSS (GPS) problem in cities
In cities, tall buildings block and reflect satellite signals, degrading GNSS accuracy. But the problem goes beyond accuracy: a standard GNSS receiver can report a position that looks tight and confident while being metres from the truth. For a human driver, that is usually an annoyance. For an autonomous vehicle with no one in the driver’s seat, “confident but wrong” is a safety problem.
This is the mindset Nasir argues the industry has to design for: “You don’t design a sensor suite for what might happen in a test lab. You design it for every edge case that can occur at 3 a.m. in a rainstorm on an unmarked rural road.”
Cameras and radar tell the vehicle what is around it; GNSS positioning tells it where it is in the world: which lane, which junction, where the boundaries are. The two are complementary. Notably, Wayve’s system uses a suite of surround cameras and radar but no lidar, which places even greater weight on the remaining inputs being trustworthy.
In an urban canyon, surrounding buildings can block or reflect GNSS signals, creating multipath errors that distort the calculated position. The challenge is rarely that the vehicle has no positioning information; it is that the system must gauge the quality of that information and recognise when it should be trusted and when it should be treated with caution. The goal is GNSS that stays reliable in exactly the urban canyons where conventional receivers struggle, so that location remains an input the vehicle can depend on.
Manuel del Castillo, VP at FocalPoint, comments, “The city is an important testbed. Solving these problems here could help accelerate autonomous mobility elsewhere, particularly in other dense urban environments. The opportunity is therefore bigger than deploying driverless taxis in London. It’s about demonstrating that autonomous systems can operate reliably in one of the world’s most complex cities – and using those lessons to make self-driving technology safer and more accessible.”
He adds, “In our own London trials, we’ve seen how quickly satellite signals degrade between tall buildings. We built S-GNSS Auto to filter out degraded or reflected signals, giving a vehicle a clearer picture of where it actually is, even in the parts of a city where GNSS struggles the most.”
A new scalable commercial model
Robotaxis are only one expression of a broader rollout, and the commercial model increasingly favours software that scales. Wayve’s partnerships extend well beyond London: the company plans a Tokyo pilot with Uber and Nissan using the Nissan Leaf, and is integrating its AI Driver software into Nissan’s ProPILOT system, bound for production in Japan from 2027.
This marks a genuine shift in how the industry is organising itself. For years, the working assumption was that each carmaker would build its own autonomy stack in-house. That model is changing, due the cost and difficulty of the task: Ford and Volkswagen wound down their jointly backed Argo AI in 2022, and GM has since folded its Cruise robotaxi programme back into the company. Building a full self-driving system and keeping it safe across every road, city and edge case has proven slow and capital-intensive for many OEMs to shoulder alone. Wayve represents the alternative: a platform that carmakers license rather than build.
Optimising the stack for reliable urban performance
Cities are the toughest environment autonomy will face, which means they are also where the technology has the most to prove, and the most to gain. Solve positioning in a place like London, where the urban canyon does its worst, and you have solved it for a great many places that are easier.
There’s a temptation, especially as robotaxi economics come under pressure, to treat safety and cost as opposing goals: to assume that spending less inevitably means accepting more risk. Adding sensors to compensate for an unreliable positioning layer is expensive and doesn’t guarantee safety. Getting more reliable, validated performance out of the sensors already in the stack does both at once.
That is the opportunity in front of the industry: not to treat degraded GNSS as an unavoidable weak point, but to turn it into a dependable input the rest of the ADAS stack can trust. This offers automotive OEMs a route to expanding the operational domain of their automated driving features into complex but everyday urban driving environments.
Cover pic: Photo by Anil Baki Durmus on Unsplash
Share this post
Ramya Sriram leads marketing at FocalPoint, a UK-based company that provides GPS-enhancing software for automotive, wearables and smartphones.
Related post
What Xona’s LEO-PNT Milestone Means for the Future of Resilient Navigation
Xona’s Pulsar constellation promises stronger signals and a valuable new layer of positioning infrastructure. In this blog post, we examine what this means for navigation and the future of resilient PNT.